Projects
Research directions, the papers behind them, and notes from the field.
1 paper · arXiv 2026
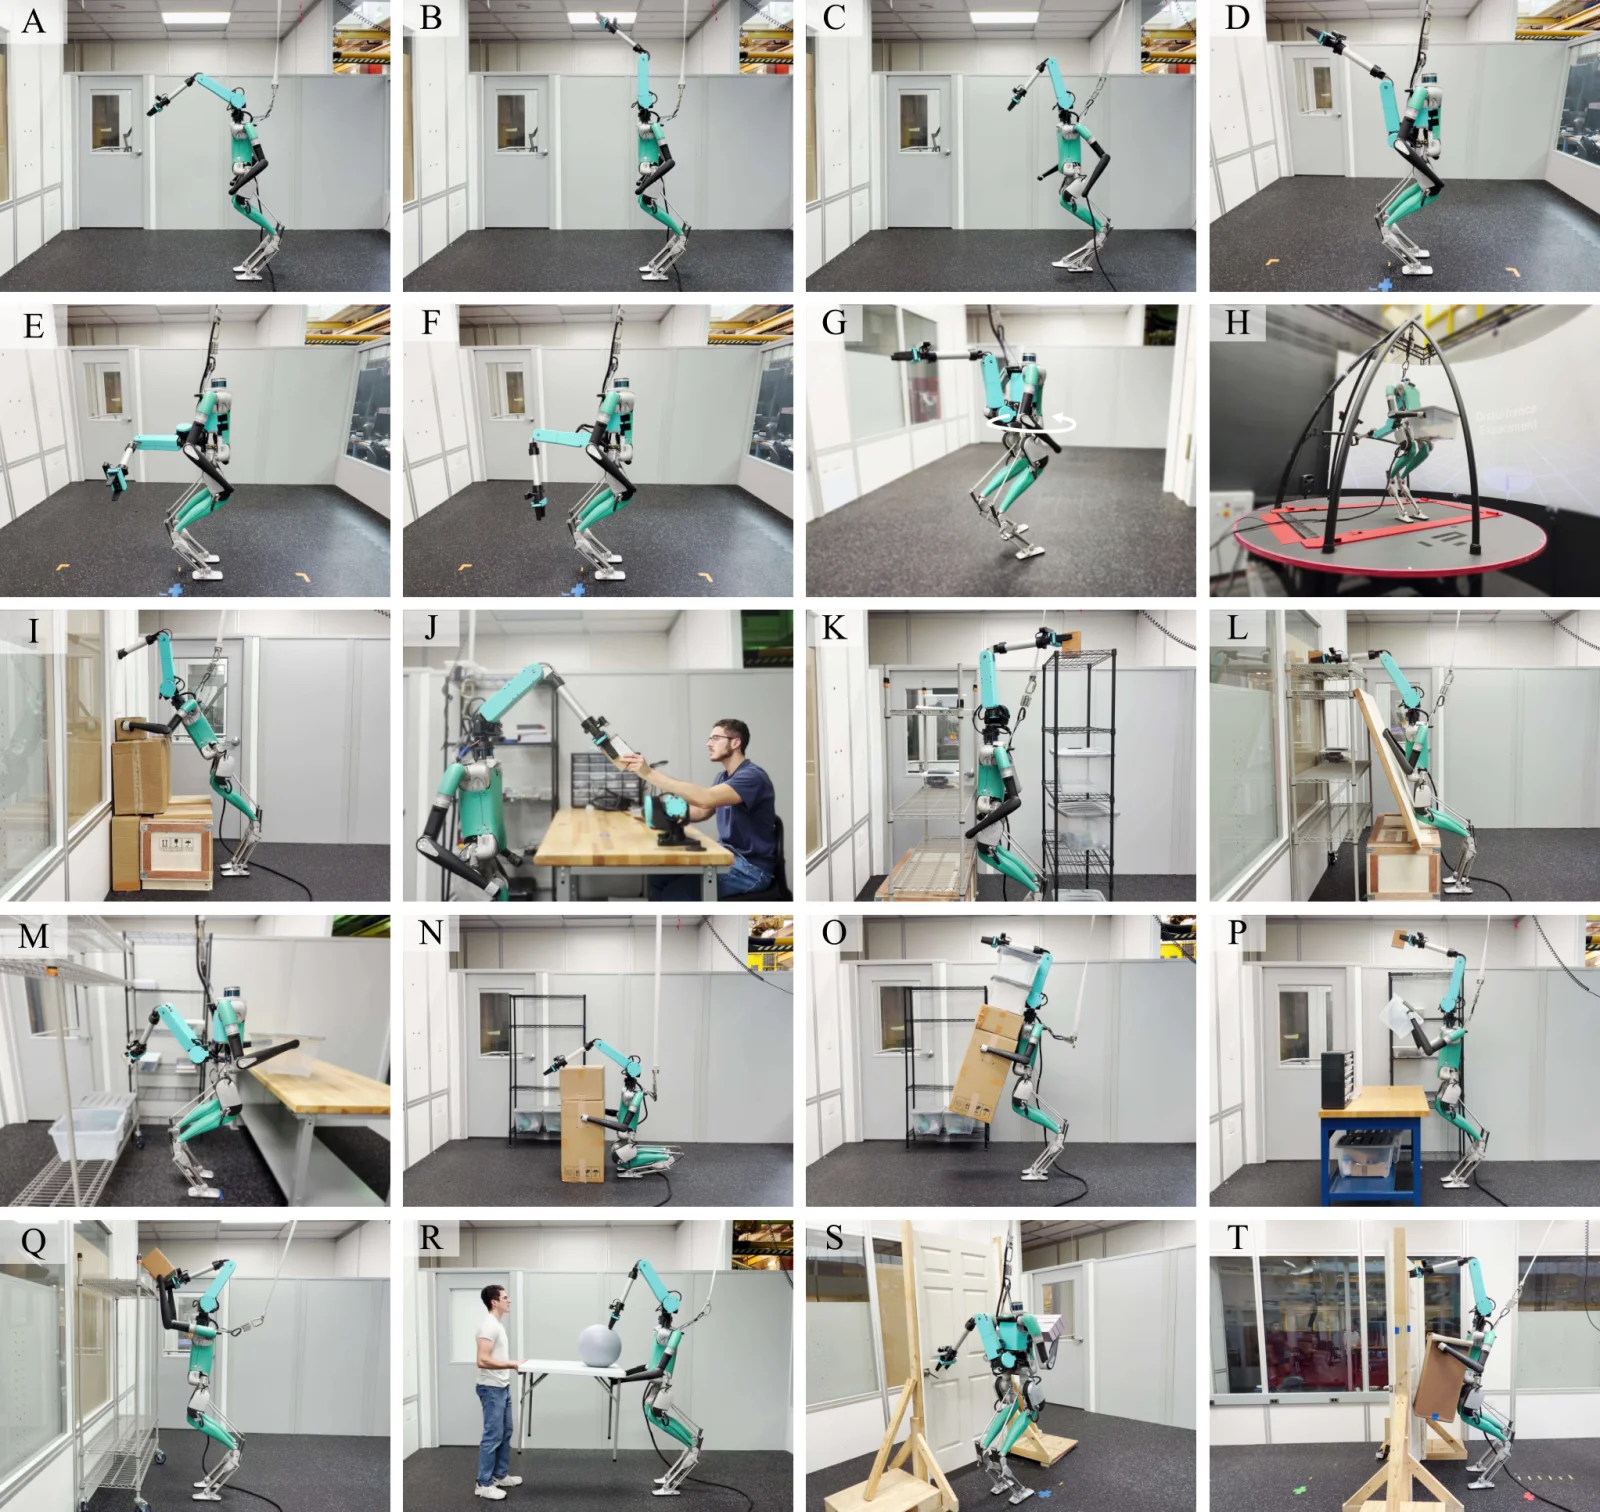
Humanoid SRL
An extra arm expands humanoid reach, support, and whole-body manipulation, with trajectory optimization and Learn-to-Teach control.
1 paper · arXiv 2026
Spectral Skills
A latent command space for humanoid control, learned by predicting motion: tracking, chaining, and composing skills on a Unitree G1.
1 paper · arXiv 2026
Locomotion on Granular Media
Granular contact physics and terrain-adaptive reinforcement learning for humanoid locomotion on shifting ground.
2 papers
Humanoid Locomotion
Learning what a walking robot should optimize, and how to train its controller efficiently. Infer and Adapt learns rewards from demonstrations; Learn to Teach uses privileged simulation information to train deployable policies.
1 paper · ICML 2026 Oral
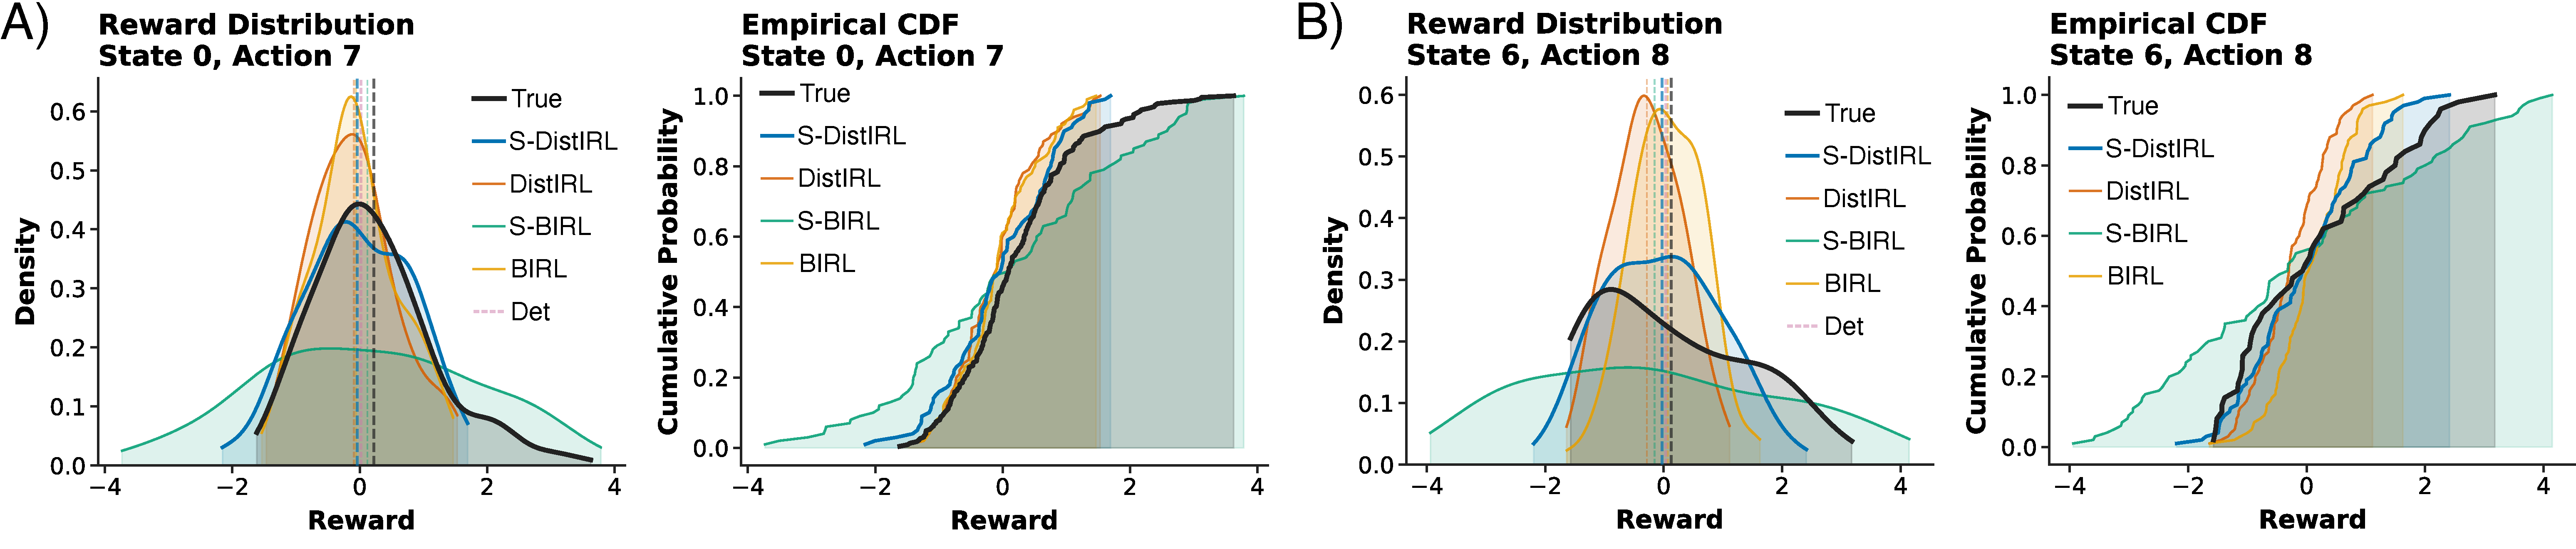
Distributional Inverse Reinforcement Learning
Recovering reward and return distributions from demonstrations for risk-aware imitation learning.
1 paper · ICRA 2026
Stable End-Effector Control
Model-enhanced residual learning for stable end-effector control during humanoid loco-manipulation.
1 paper · ICRA 2026
RL-augmented Adaptive MPC
RL corrections to adaptive MPC so bipedal locomotion stays accurate on challenging terrain.