Feiyang Wu
My research interests lie in the intersection of optimization, reinforcement learning, and robotics. I develop algorithms to efficiently train robots, ideally with theoretical guarantee.
I am an ML PhD student at Georgia Tech, co-advised by Prof. Anqi Wu and Prof. Ye Zhao. Additionally, I had the privilege to collaborate with Prof. George Lan on stochastic optimization and RL.
News
Nov 2026 Spectral Skills won a second award: the Best Paper Award at the Compositional Generalization workshop, CoRL 2026!
Oct 2026 Our Humanoid SRL paper is now on arXiv!
Sep 2026 Our Spectral Skills workshop paper won the ROBOTIS Best Paper Award (1st place) at CompRobotis, IROS 2026!
Sep 2026 Our paper Spectral Skills is on arXiv: a latent command space for humanoid control that tracks, chains, and composes skills. Blog.
Earlier news
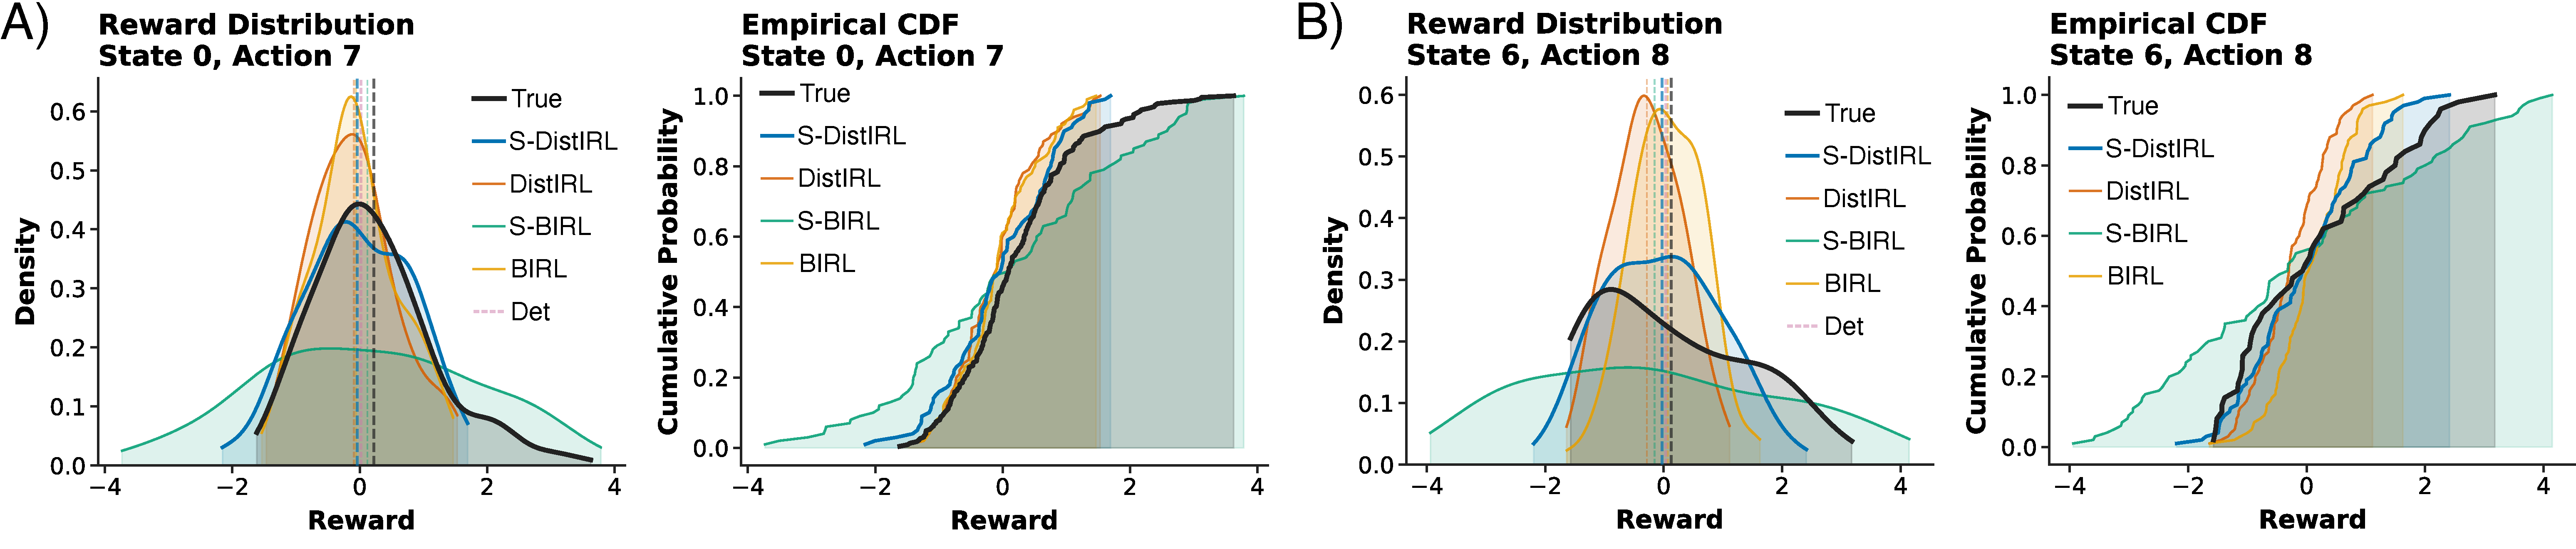
May 2026 Our Distributional Inverse Reinforcement Learning paper was upgraded to an oral presentation at ICML 2026!
May 2026 Our RA-L paper Learn to Teach was selected for an oral presentation at ICRA 2026!
Apr 2026 We deployed the L2T policy on Digit aboard the Navy’s Stiletto. Field notes and videos.
Apr 2026 Our paper Distributional Inverse Reinforcement Learning was accepted as an ICML 2026 spotlight!
Jan 2026 Two papers accepted to ICRA 2026!
Sep 2025 Our work on IRL with reward distributions is released on arXiv.
Aug 2025 Our paper L2T got accepted at RA-L. Check out here.
May 2025 I passed my qualifying exam.
May 2025 One paper accepted to ICML 2025. Congrats Jingyang!
Apr 2025 One paper submitted to RA-L. Check out lidar-learn-to-teach.github.io.
Sep 2024 Visiting student Xavier Nal finished his master’s project in our lab.
May 2024 Interned at Georgia Tech Research Institute on generalizing diffusion policies for robot manipulation.
Dec 2023 Our paper on inverse reinforcement learning accepted to ICRA 2024.
Oct 2023 Our paper on average reward IRL accepted as poster at NeurIPS 2023.
Selected publications
All publications
arXiv preprint, 2026
arXiv preprint, 2026
Best Paper Award — Compositional Generalization for Real-World Robot Learning, CoRL 2026 (workshop version)
ROBOTIS Best Paper Award (1st place) — CompRobotis, IROS 2026 (workshop version)
ROBOTIS Best Paper Award (1st place) — CompRobotis, IROS 2026 (workshop version)
arXiv preprint, 2026
ICML 2026 Oral (0.7% acceptance rate)
ICRA 2026
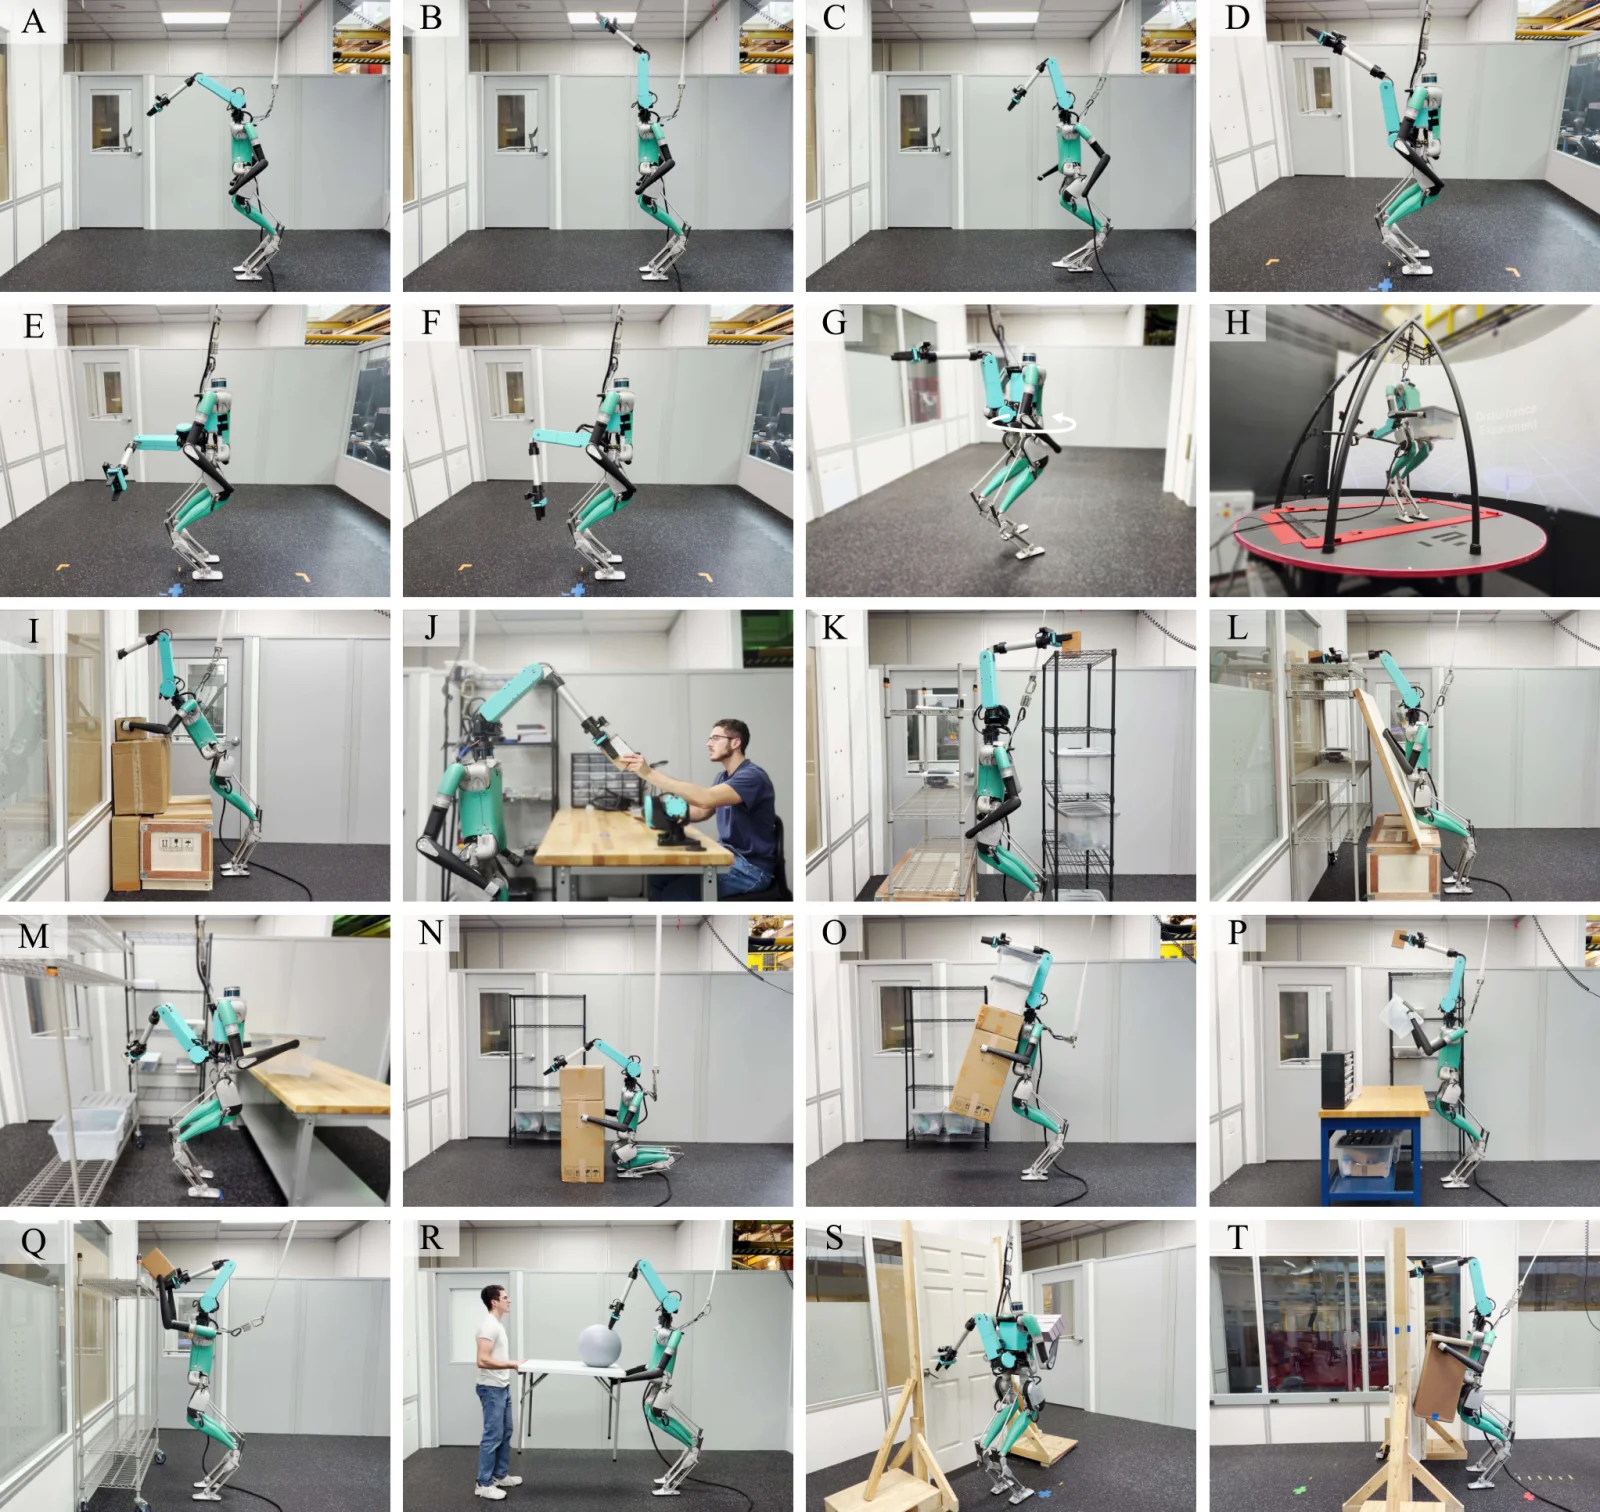
SEEC: Stable End-Effector Control with Model-Enhanced Residual Learning for Humanoid Loco-Manipulation
ICRA 2026
★ Learn to Teach: Sample-Efficient Privileged Learning for Humanoid Locomotion over Real-World Uneven Terrain
RA-L 2025, ICRA 2026 Oral
Mathematics of Operations Research 2025
Infer and Adapt: Bipedal Locomotion Reward Learning from Demonstrations via Inverse Reinforcement Learning
ICRA 2024
IEEE Transactions on Visualization and Computer Graphics (TVCG) 2020